HF 論文速讀 2026-08-11
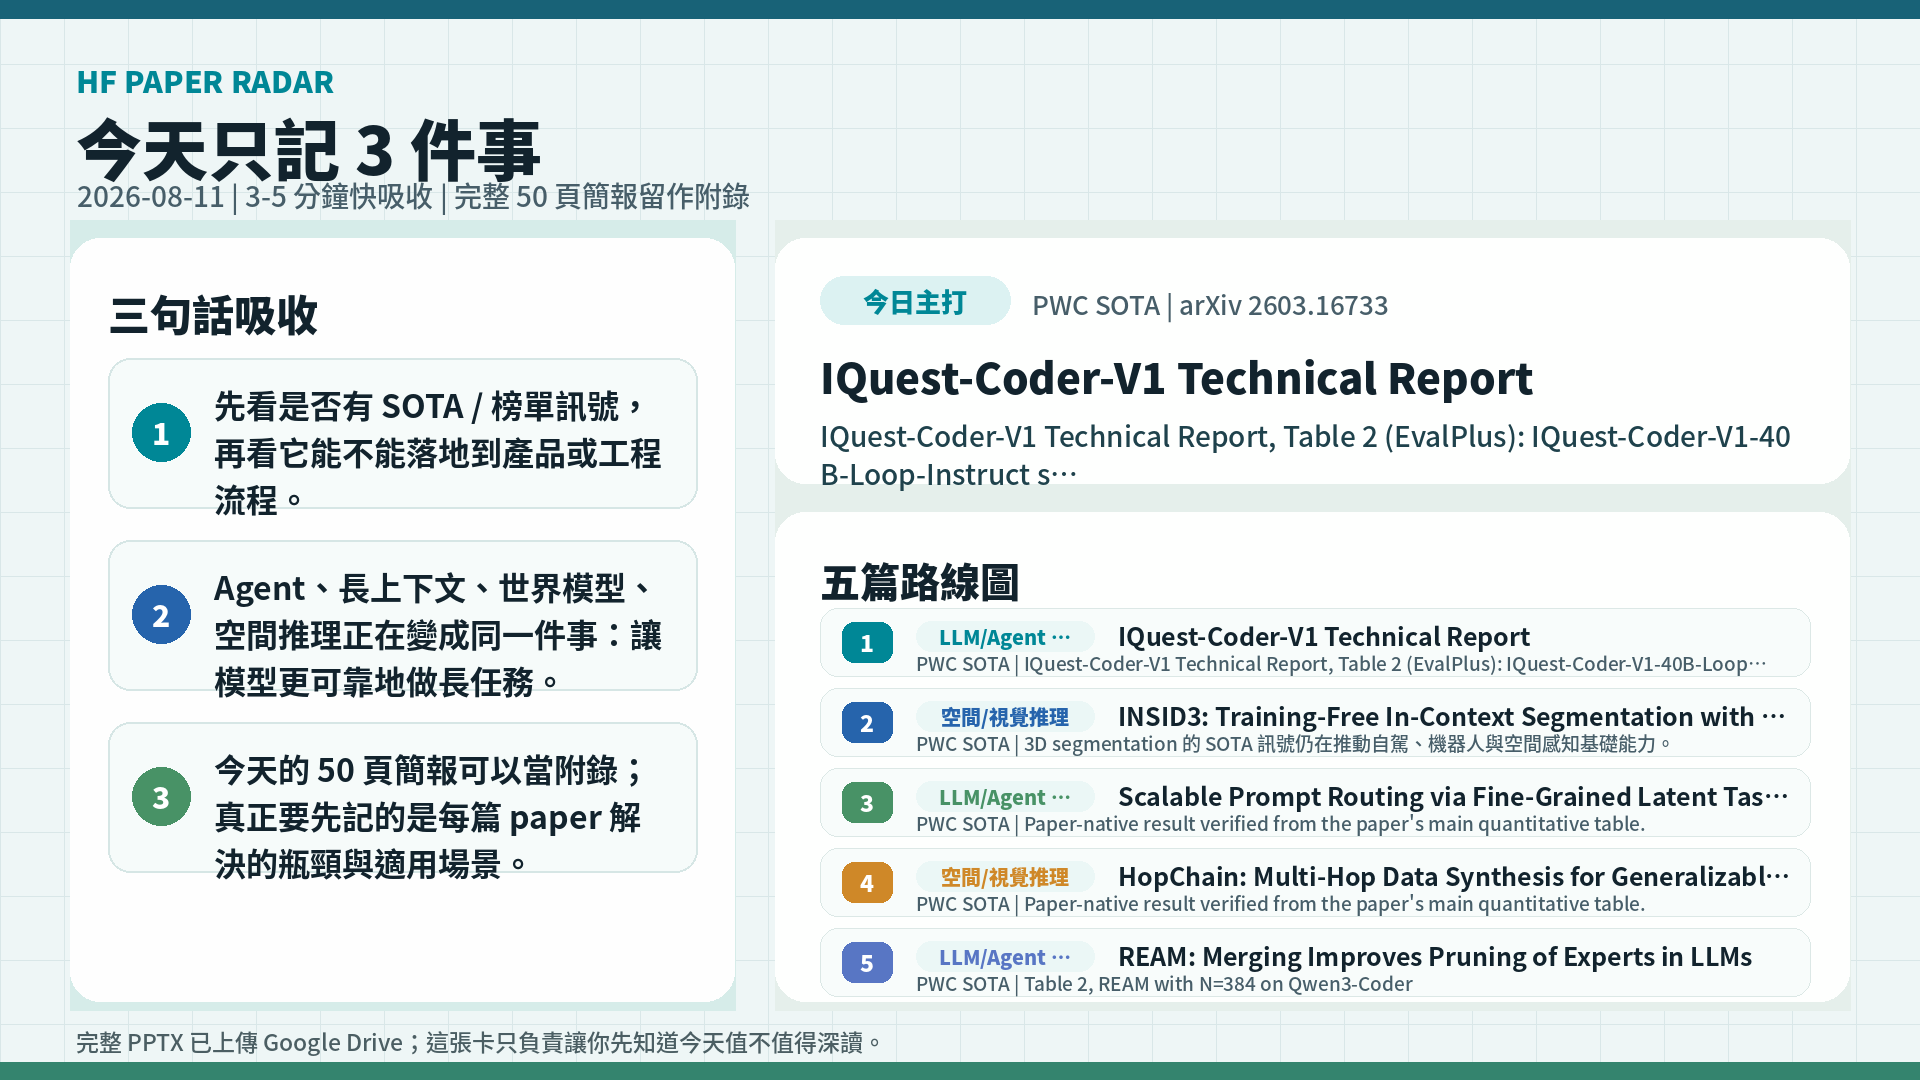
今天的共同趨勢:AI 研究正在從模型能力本身,推進到長任務、長上下文、空間感知與可驗證環境。
今天先追 IQuest-Coder-V1 Technical Report,再用另外四篇補齊 Agent、robotics、spatial reasoning、context efficiency 與 SOTA 感知能力的路線圖。
今天先記三件事
- 先看是否有 SOTA / 榜單訊號,再看它能不能落地到產品或工程流程。
- Agent、長上下文、世界模型、空間推理正在變成同一件事:讓模型更可靠地做長任務。
- 今天的 50 頁簡報可以當附錄;真正要先記的是每篇 paper 解決的瓶頸與適用場景。
五篇速讀
IQuest-Coder-V1 Technical Report
LLM/Agent 基…
為什麼重要:IQuest-Coder-V1 Technical Report, Table 2 (EvalPlus): IQuest-Coder-V1-40B-Loop-Instruct s…
帶走什麼:IQuest-Coder-V1 Technical Report, Table 2 (EvalPlus): IQuest-Coder-V1-40B-Loop-Instruct s…
下一步:先看問題設定與 benchmark,再決定是否需要讀完整簡報。
INSID3: Training-Free In-Context Segmentation with DINOv3
空間/視覺推理
為什麼重要:3D segmentation 的 SOTA 訊號仍在推動自駕、機器人與空間感知基礎能力。
帶走什麼:3D segmentation 的 SOTA 訊號仍在推動自駕、機器人與空間感知基礎能力。
下一步:先看問題設定與 benchmark,再決定是否需要讀完整簡報。
Scalable Prompt Routing via Fine-Grained Latent Task Discovery
LLM/Agent 基…
為什麼重要:Paper-native result verified from the paper's main quantitative table.
帶走什麼:Paper-native result verified from the paper's main quantitative table.
下一步:先看問題設定與 benchmark,再決定是否需要讀完整簡報。
HopChain: Multi-Hop Data Synthesis for Generalizable Vision-Language Reasoning
空間/視覺推理
為什麼重要:Paper-native result verified from the paper's main quantitative table.
帶走什麼:Paper-native result verified from the paper's main quantitative table.
下一步:先看問題設定與 benchmark,再決定是否需要讀完整簡報。
REAM: Merging Improves Pruning of Experts in LLMs
LLM/Agent 基…
為什麼重要:Table 2, REAM with N=384 on Qwen3-Coder
帶走什麼:Table 2, REAM with N=384 on Qwen3-Coder
下一步:先看問題設定與 benchmark,再決定是否需要讀完整簡報。